sandbox/jieyun/test/zalesak_vof.c
Zalesak’s disk with the VOF method
In the Zalesak’s disk test case, a notched circular interface is rotated by a constant velocity field (u, v) = (2 \pi (0.5 - y), 2 \pi (x - 0.5))
scalar f[];
scalar * interfaces = {f}, * tracers = NULL;

#include "advection-ebit.h"
#include "vof.h"

const char *OUTNAME = "zalesak";
const double xcenter = 0.5, ycenter = 0.75, R = 0.15;
double EndT = 1. [0, 1];
double ddt;
int IT, level;
double tTime = 0., area0, area;

int main() {
  for (level = 6; level < 7; level++) {
    init_grid (1 << level);
    ddt = 1. [0, 1]/N/16.;
    IT = 16*N;
    run();
  }
}
Function used for a notched circle.
double rectangle (double x, double y, coord center, coord size) {
  double P1_Plus = x - size.x/2.  - center.x;
  double P1_Minus = x + size.x/2. - center.x;
  double P1 = max (P1_Plus, -P1_Minus);

  double P2_Plus = y - size.y/2.  - center.y;
  double P2_Minus = y + size.y/2. - center.y;
  double P2 = max (P2_Plus, -P2_Minus);

  double c = max (P1, P2);
  return c;
}

double circle (double x, double y,  coord center, double radius) {
  double R2 = sq(x - center.x) + sq (y - center.y);
  return sqrt(R2) - radius;
}

double geometry (double x, double y) {
  coord center_circle, center_rectangle, size_rectangle;
  center_circle.x = center_rectangle.x = 0.5;
  center_circle.y = 0.75;

  center_rectangle.y = 0.725;

  size_rectangle.x = 0.05;
  size_rectangle.y = 0.25;

  double s = -circle (x, y, center_circle, 0.15);
  double r = -rectangle (x, y, center_rectangle, size_rectangle);

  double zalesak = difference(s, r) ;

  return zalesak;
}

event init (i = 0) {
  tTime = 0.;
  vertex scalar phi[];
  foreach_vertex()
    phi[] = geometry (x,y);

  fractions (phi, f);

  stats stat_f = statsf (f);
  area0 = stat_f.sum;
}
The timestep dt and the velocity field are set.
event stability (i++, i < IT, first) {
  dt = dtnext (ddt);
  double u0 = 2. [1, -1];

  foreach_face(x)
    uf.x[] = u0*pi*(0.5 - y/L0);

  foreach_face(y)
    uf.y[] = u0*pi*(x/L0 - 0.5);

  tTime += dt;
}

event interface_out (i++, last) {
  if (2*(i + 1) % max(IT, 1) == 0 || i == 0) {
    int ii = 2*(i + 1)/max(IT, 1);
    char name[80];
    sprintf (name, "%s_vof_%d_%d.dat", OUTNAME, N, ii);

    FILE * fp;
    fp = fopen (name, "w");
    output_facets (f, fp);
    fclose (fp);
  }
}
We can compute the shape error (E_{shape}) and area error (E_{area}).
E_{shape}=\max_{i}| \mathrm{dist} (\boldsymbol{x}_i)| . \mathrm{dist}(\boldsymbol{x}_i)=\sqrt{(x_i - x_c)^2 + (y_i - y_c)^2} - R where the reference solution is a circle centered in (x_c,y_c) and with radius R.
E_{area} = (A(T) - A(0)) / A(0).
event calc_infty_norm (t = end) {
  // calculate the shape error based on the two end points of interface segment
  face vector s_f[];
  s_f.x.i = -1;
  double l_inf = 0.;
  foreach(reduction(max:l_inf))
    if (f[] > 1e-6 && f[] < 1. - 1e-6) {
      coord n = facet_normal (point, f, s_f);
      double alpha = plane_alpha (f[], n);

      coord segment[2];
      if (facets (n, alpha, segment) == 2) {
        for (int ii = 0; ii < 2; ii++) {
          double x1, y1, dist;
          x1 = x + segment[ii].x*Delta;
          y1 = y + segment[ii].y*Delta;
          dist = fabs(sqrt(sq(x1 - xcenter) + sq(y1 - ycenter)) - R);
          if (dist > l_inf ) l_inf = dist;
        }
      }
    }

  stats stat_f = statsf (f);
  area = stat_f.sum;

  // shape error and area error
  printf ("%d %e %e %e %e\n", N, area0, area, fabs(area0 - area)/area0, l_inf);

  // reference file
  output_facets (f, stderr);
}
Results
The shapes of the interface at t = T/2 and t = T are displayed below.
reset
set size ratio -1
plot [0.:1.][0.:1.]'zalesak_vof_64_1.dat' w l lw 3 t "VOF, t = T/2", \
  'zalesak_vof_64_2.dat' w l lw 3 t "VOF, t = T", \
  '../zalesak_ana_2.dat' w l dt 2 t "Ref. t = T/2", \
  '../zalesak_ana_4.dat' w l dt 2 t "Ref. t = T"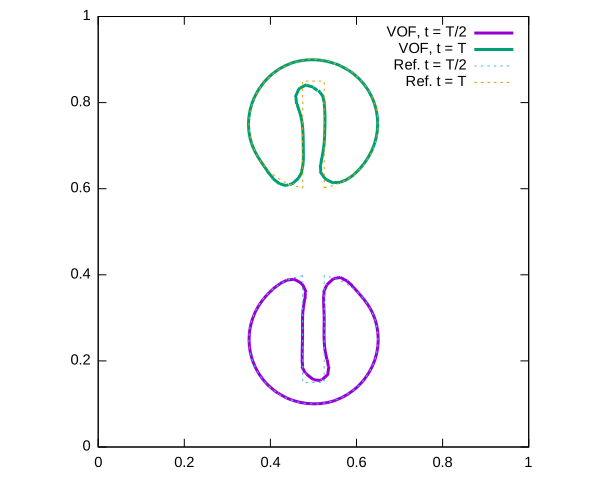
See also
References
| [zalesak1979] |
Steven T. Zalesak. Fully multidimensional flux-corrected transport algorithms for fluids. Journal of Computational Physics, 31:335–362, 1979. |