sandbox/jieyun/tag/tag.h
Tagging connected neighborhoods
The goal is to associate a unique (strictly positive) index (“tag”) t to cells which belong to the same “neighborhood”. All cells in a neighborhood have an initial tag value (given by the user) which is non-zero and are separated from cells in other neighborhoods by cells which have an initial (and final) tag value of zero.
We first define the restriction function for tag values. The parent tag is just the minimum of its children’s tags.
static void restriction_tag (Point point, scalar t)
{
  double min = HUGE;
  foreach_child()
    if (t[] < min)
      min = t[];
  t[] = min;
}
We also need a few helper functions. The function below implements a binary search of a sorted array. It returns the index in the array so that a[s] \leq tag < a[s+1].
static long lookup_tag (Array * a, double tag)
{
  long len = a->len/sizeof(double);
  double * p = (double *) a->p;
  if (tag == p[0])
    return 0;
  if (tag == p[len - 1])
    return len - 1;

  long s = 0, e = len - 1;
  while (s < e - 1) {
    long m = (s + e)/2;
    if (p[m] <= tag)
      s = m;
    else
      e = m;
  }
  return s;
}

#if _MPI
static int compar_double (const void * p1, const void * p2)
{
  const double * a = p1, * b = p2;
  return *a > *b;
}
#endif
The function just takes the scalar field t which holds the initial and final tag values. It returns the maximum neighborhood tag value (which is also the number of neighborhoods).
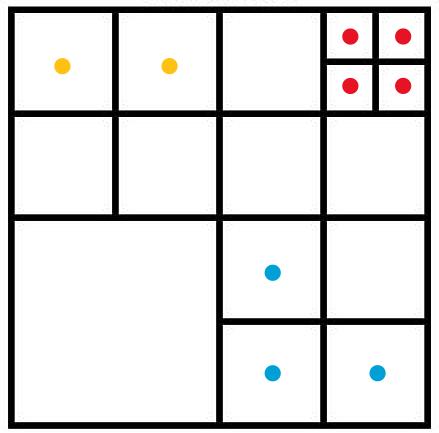
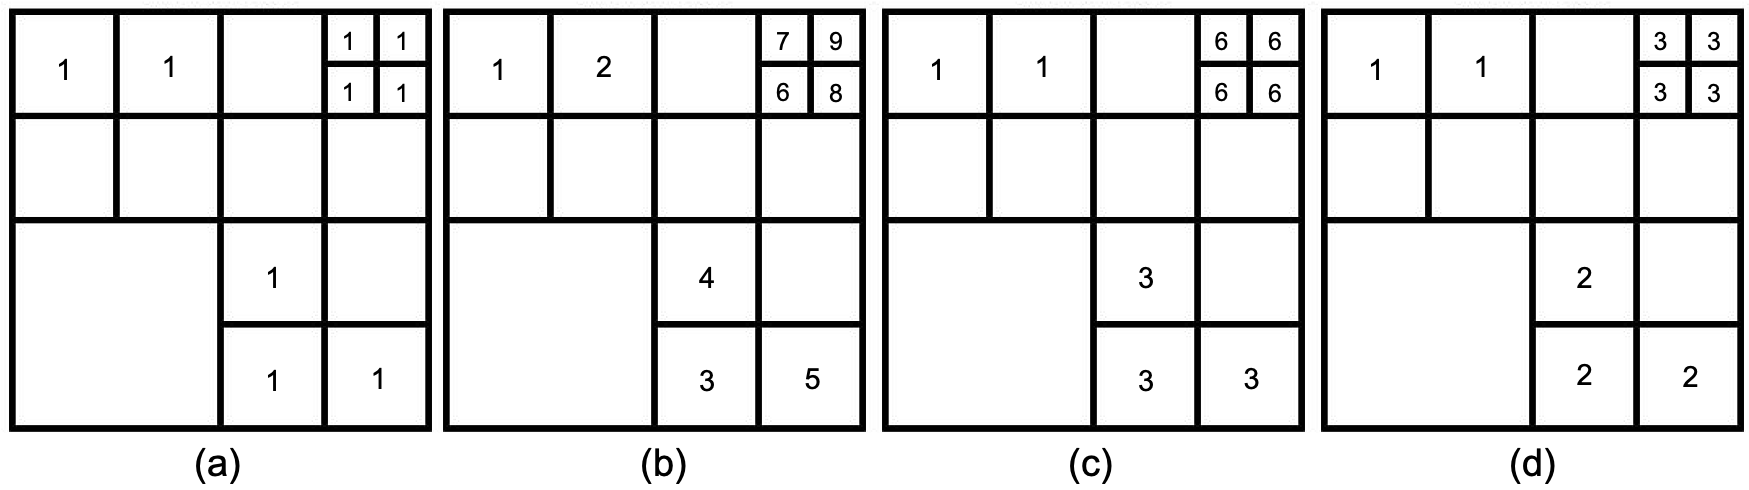
For example, the leaf cell with a positive initial tag value is marked by color dot (Fig. 1), the color of dot is based on the neighborhood to which the cell belongs. Then the tag function will return “3”, which is the number of connected neighborhoods. For this sample case, Fig. 2(a) and Fig. 2(d) show the intial tag value and the final tag value of each leaf cell (cells with 0 tag value are not shown).
We first set the restriction and prolongation functions (on trees).
  t.restriction = restriction_tag;
#if TREE
  t.refine = t.prolongation = refine_injection;
  t.dirty = true;
#endif
As an initial guess, we set all the (leaf) cells which have a non-zero initial tag value to the Z- (or Morton-) index. We thus have a different “neighborhood” for each cell which has a non-zero initial tag, and a single neighborhood (tagged zero) for all the cells which have a zero initial tag. See Fig. 2(a) to Fig. 2(b)
#if _MPI
  scalar index[];
  z_indexing (index, true);
  foreach()
    t[] = (t[] != 0)*(index[] + 1);
#else // !_MPI
  long i = 1;
  foreach_cell()
    if (is_leaf(cell)) {
      t[] = (t[] != 0)*i++;
      continue;
    }
#endif // !_MPI
To gather cells which belong to the same neighborhood, we repeat multigrid iterations until none of the tag values changes. The cells belonging to the same neighborhood will be tagged by the same index, which is the mininum initial tag value of these cells.
  bool changed;
  do {
We first do a restriction from the finest to the coarsest level of
the multigrid hierarchy, using the restriction_tag()
function above.
restriction ({t});We then go from the coarsest to the finest level and update the tag values.
    changed = false;
    for (int l = 1; l <= grid->maxdepth; l++) {
If the parent tag is non-zero, we set the child tag to the value of its parent (i.e. to the minimum tag value of its siblings).
      foreach_level(l)
        if (coarse(t))
          t[] = coarse(t);
            boundary_level ({t}, l);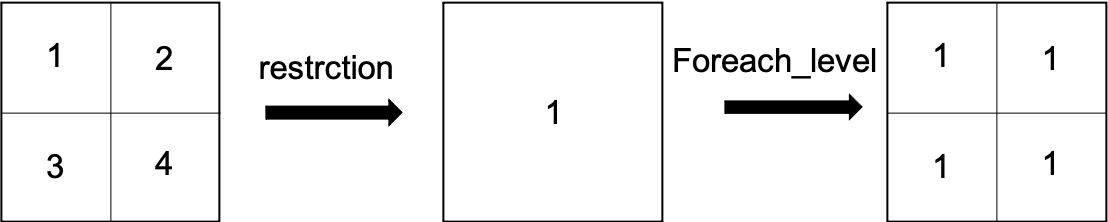
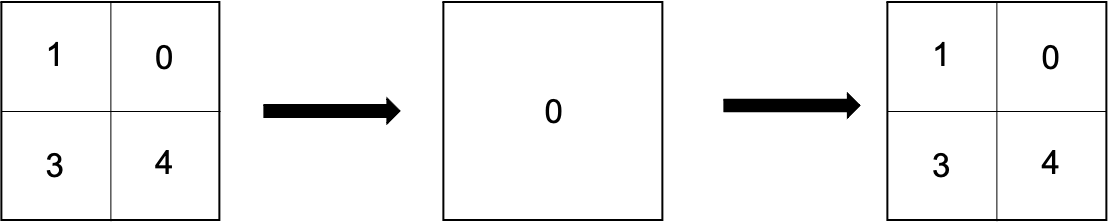
Figure 3. restriction_tag() function
After the “restriction” and the “foreach_level” steps, if the child cells belonging to the same parent cell are all marked, the tags of these child cells will be set to the correct value. (i.e. to the minimum tag value of its siblings), see Fig. 3(a). Otherwise, the tags value of these child cells are unchanged, see Fig. 3(b).
For cells which verify the threshold condition (i.e. for which
t[] != 0), we refine this initial guess by taking the
minimum (non-zero) tag value of its closest neighbors (merging). We also
track whether this update changes any of the tag values.
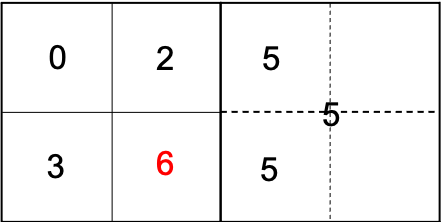
On trees, the neighboring leaf cell may belong to differet level. For example, suppose we are searching the neighbors of cell “6” in Fig. 4. In order to get tag informtion from coarser level, we need to set the tag value (“5”) of ghost cell (dash line) correctly by the “refine_injection” prolongation method (boundary_level trigers the prolongation).
      foreach_level (l, reduction(||:changed))
        if (t[]) {
        double min = t[];
        foreach_neighbor(1)
          if (t[] && t[] < min)
            min = t[];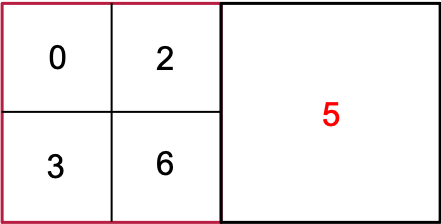
On other hand, on trees, we need to take into account the minimum tag value of neighboring fine cells. For example, suppose we are searching the neighbors of cell “5” in Fig. 5. Because the tag value of the parent cell (red solid) is zero, we need to get the tag values of finer leaf cell by the following foreach_dimension iterator.
#if TREE
        foreach_dimension()
          for (int i = -1; i <= 2; i += 3)
            if (is_refined (neighbor((2*i - 1)/3)))
        for (int j = 0; j <= 1; j++)
          for (int k = 0; k <= 1; k++)
            if (fine(t,i,j,k) && fine(t,i,j,k) < min)
              min = fine(t,i,j,k);
#endif // TREE

	  if (t[] != min) {
	    changed = true;
	    t[] = min;
	  }
	}
      boundary_level ({t}, l);
    }
  } while (changed);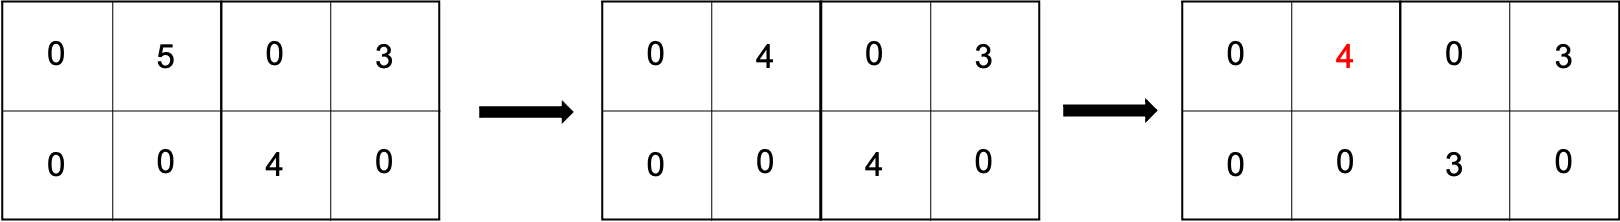
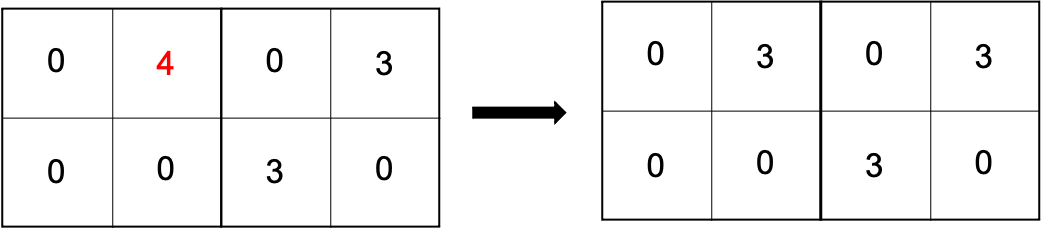
Figure 6. Effect of searching order
Due to the traversal order of cells, the tag value of cells may not be set to a correct after only one round of merging procedure. Fig. 6(a) illustrate one of these cases, we fisrt search the neighboring cells for cell “5”, then that for cell “4”. After one round of merging, the tag of “5” becomes “4”, but the correct tag value is “3”. This problem can be solved by above iterative algorithm, the flag “changed” is used keep tracking the change of tag. For example in Fig. 6(b), after the second round, the tags are all set to the correct values. Fig. 1(b) to Fig. 1(c) show the change of tags after above iterative merging procedure.
Reducing the range of indices
Each neighborhood is now tagged with a unique index. The range of indices is large however (between one and the total number of leaves). The goal of this step is to reduce this range to between one and the number of neighborhoods. Fig. 1(c) to Fig. 1(d) illustrate this reducing procedure. To do this, we create an ordered array of unique indices.
We first check whether the index is larger than the maximum or smaller than the minimum value in the array. s is the position of the (possibly new) index in the array. A negative value means that the index is already in the array.
      double tag = t[], * ap = (double *) a->p;
      long s = -1;
      if (a->len == 0 || tag > ap[a->len/sizeof(double) - 1])
	      s = a->len/sizeof(double);
      else if (tag < ap[0])
	      s = 0;
      else {
We find the range of existing indices [s-1:s] which contains the index. We check whether the index is already in the array.
        s = lookup_tag (a, tag) + 1;
        if (tag == ap[s - 1] || tag == ap[s])
          s = -1;
      }
      if (s >= 0) {
If the index is new, we add it to the array in the correct position (s). The array “ap” will be [1, 3, 6] for the example in Fig. 2(c)
        array_append (a, &tag, sizeof(double)), ap = (double *) a->p;
        for (int i = a->len/sizeof(double) - 1; i > s; i--)
          ap[i] = ap[i-1];
        ap[s] = tag;
      }
    }
Parallel reduction
Each process now has its own local correspondence map between the neighborhood index and its rank in the array a (i.e. its reduced index). In parallel, we now need to build a global correspondence map.
We first get the maximum size over all processes of the local map and increase the size of the local map to this value.
#if _MPI
  long lmax = a->len;
  mpi_all_reduce (lmax, MPI_LONG, MPI_MAX);
  a->p = realloc (a->p, lmax);
  lmax /= sizeof(double);
We then gather all the local maps into a global map and sort it. All local arrays need to be of the same size to be able to use MPI_Allgather(), so we first pad the arrays with -1.
  double * q = a->p;
  for (int i = a->len/sizeof(double); i < lmax; i++)
    q[i] = -1;
  double p[lmax*npe()];
  MPI_Allgather (a->p, lmax, MPI_DOUBLE, p, lmax, MPI_DOUBLE, MPI_COMM_WORLD);
  qsort (p, lmax*npe(), sizeof(double), compar_double);
This sorted global map will (probably) contain duplicated entries (i.e. indices of neighborhoods which span multiple processes). To build the new global map (stored in a), we eliminate these, as well as the negative indices which were used to pad the local arrays.
  array_free (a);
  a = array_new();
  double last = -1;
  for (int i = 0; i < lmax*npe(); i++)
    if (p[i] != last) {
      array_append (a, &p[i], sizeof(double));
      last = p[i];
    }
#endif
Once we have the (global) map, we can replace the neighborhood indices with their index in the global map (+1).
  foreach()
    if (t[] > 0)
      t[] = lookup_tag (a, t[]) + 1;
We return the maximum index value.
  int n = a->len/sizeof(double);
  array_free (a);
  return n;
}
Removing (small) droplets/bubbles
Using tag(), the function below can identify and remove droplets (or bubbles) defined by VOF tracer f (resp. 1 - f), smaller than a given diameter (minsize) expressed in number of cells.
struct RemoveDroplets {
  scalar f;         // compulsory
  int minsize;      // default 3
  double threshold; // default 1e-4
  bool bubbles;     // default false
};

void remove_droplets (struct RemoveDroplets p)
{
  scalar d[], f = p.f;
  double threshold = p.threshold ? p.threshold : 1e-4;
  foreach()
    d[] = (p.bubbles ? 1. - f[] : f[]) > threshold;
  int n = tag (d), size[n];
  for (int i = 0; i < n; i++)
    size[i] = 0;
  foreach (serial)
    if (d[] > 0)
      size[((int) d[]) - 1]++;
#if _MPI
  MPI_Allreduce (MPI_IN_PLACE, size, n, MPI_INT, MPI_SUM, MPI_COMM_WORLD);
#endif
  int minsize = pow (p.minsize ? p.minsize : 3, dimension);
  foreach()
    if (d[] > 0 && size[((int) d[]) - 1] < minsize)
      f[] = p.bubbles;
}